
 Kontakt
 Kako kupovati

Dostava
Savjetnik za kupnju
 Engleski
 373 b
Do 30 dana za povrat
Kupci su kupili i


 /
 Adobe ePub DRM
 161.31
€



 /
 Meki uvez
86.85
€


 /
Meki uvez
24.07
€


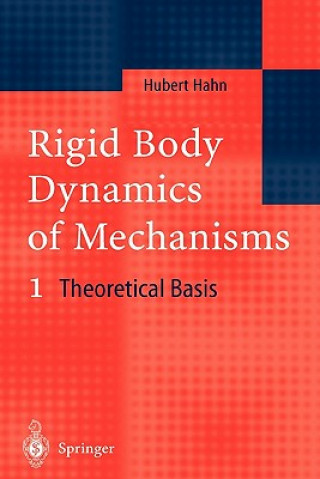
This monograph presents an introduction into basic mechanical aspects of mechatronic systems for students, researchers and engineers from industrial practice. An overview over the theoretical background of rigid body mechanics is given as well as a systematic approach for deriving and solving model equations of general rigid body mechanisms in the form of differential-algebraic equations (DAE). The objective of this book is to prepare the reader for being capable of efficiently handling and applying general purpose rigid body programs to complex mechanisms. The reader will be able to set up symbolic mathematical models of planar and spatial mechanisms in DAE-form for computer simulations, often required in dynamic analysis and in control design.This monograph presents an introduction into basic mechanical aspects of mechatronic systems for students, researchers and engineers from industrial practice. An overview over the theoretical background of rigid body mechanics is given as well as a systematic approach for deriving and solving model equations of general rigid body mechanisms in the form of differential-algebraic equations (DAE). Objective of this book is to prepare the reader for being capable of efficiently handling and applying general purpose rigid body programs to complex mechanisms. The reader will be able to set up symbolic mathematical models of planar and spatial mechanisms in DAE-form for computer simulations, often required in dynamic analysis and in control design.


Informacije o knjizi
Engleski

Poklonite ovu knjigu još danas
To je jednostavno
1 Dodajte knjigu u košaricu i odaberite isporuku kao poklon 2 Zauzvrat ćemo vam poslati kupon 3 Knjiga dolazi na adresu poklonoprimcaMoglo bi vas zanimati i
 /
Tvrdi uvez
51.28
€


 /
Meki uvez
24.98
€


 /
Meki uvez
37.17
€

 /
Meki uvez
11.38
€


 /
Tvrdi uvez
133.30
€


Dobar dan! Ja sam Libroamiko, vaš književni savjetnik.
Kako vam mogu pomoći?